
Biography
I am pursuing my master’s degree at SAI, Shanghai Jiao Tong University. I am supervised by Prof. Cewu Lu and Prof. Jianhua Sun. I have great research interest in embodied manipulation inspired by physial object/embodiment understanding. Previously, I got my B.Eng. degree in SJTU.
Email: wjd_kznwl@sjtu.edu.cn
Publications
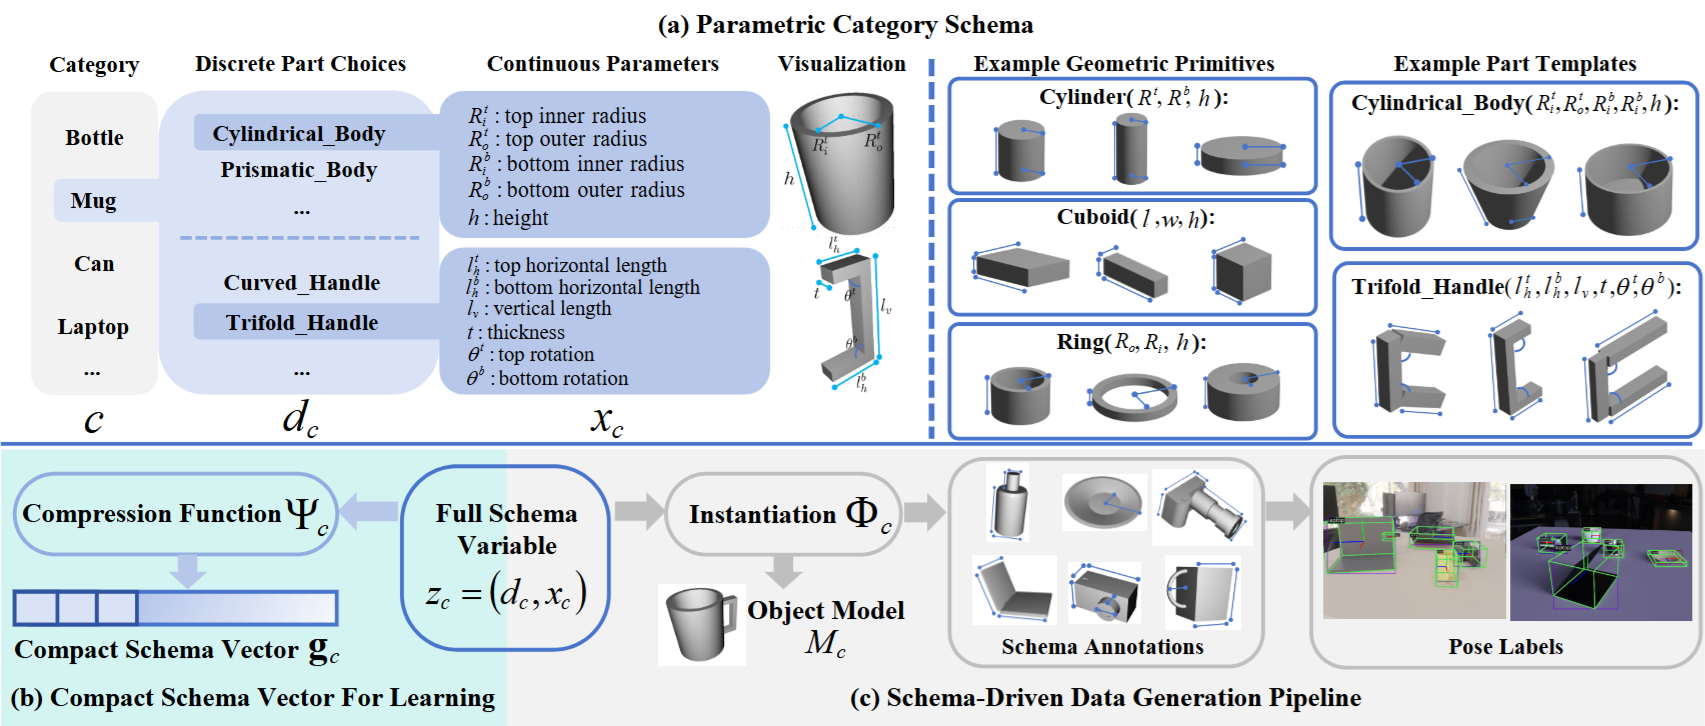
SchemaPose: RGB-Based Category-Level Pose Estimation with Parametric Category Schema
Shuang Wu, Jiude Wei, Cewu Lu, Jianhua Sun§
NeurIPS 2026
TL;DR
We propose SchemaPose, a digital-gene-guided framework for category-level 9D pose estimation that captures shared structure and instance variation, refines candidate poses with structural priors, and uses a consistent data pipeline to generate training supervision.
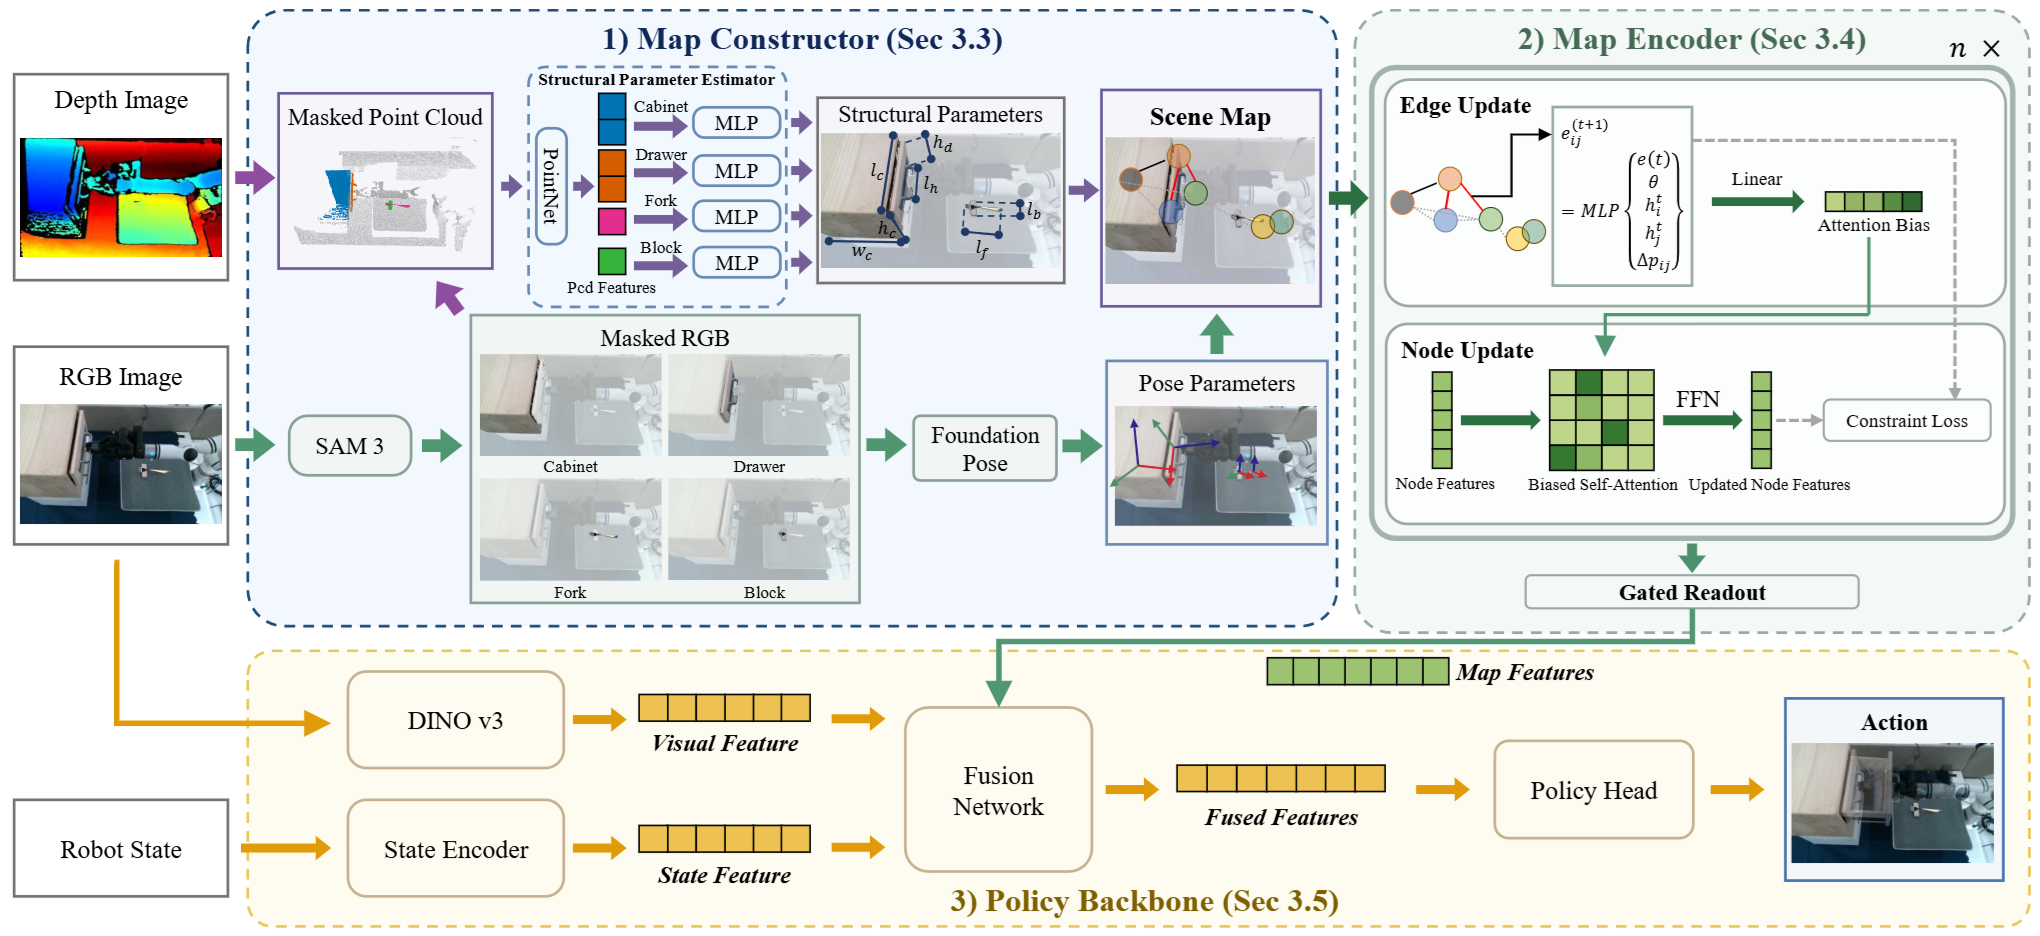
Zehao Du, Zheng Huang, Rui Li, Hongyu Liu, Jiude Wei, Jiachun Bao, Cewu Lu, Jianhua Sun§
NeurIPS 2026
TL;DR
We propose MapPolicy, a structure-aware IL framework that represents object geometry, part structure, and scene layout as digital-gene graphs, enabling robust manipulation under partial observation by fusing structural reasoning with visual observations and robot states.

StructPolicy: Structure-Guided Imitation Learning Robust to Visual Domain Shifts
Zehao Du*, Jiude Wei*, Cewu Lu, Jianhua Sun§
ECCV 2026
TL;DR
We propose StructPolicy, a lightweight structure-aware module that extracts task-relevant structural cues from visual observations to guide imitation learning, improving manipulation robustness against visual distribution shifts.

Empowering Precise Embodied Agents with Executable Analytic Concepts as Semantic-Physical Blueprints
Mingyang Sun, Jiude Wei, Qichen He, Donglin Wang, Cewu Lu, Jianhua Sun§
IJCAI 2026
TL;DR
We propose GRACE, a training-free framework that bridges VLM reasoning and precise robot execution through executable analytic concepts, enabling semantic-to-physical grounding and zero-shot generalization for articulated-object manipulation tasks.

Phsyically Ground Commonsense Knowledge for Articulated Object Manipulation with Analytic Concepts
Jiude Wei, Yuxuan Li, Cewu Lu, Jianhua Sun§
CVPR 2026
TL;DR
We introduce Analytic Concepts as the bridge between the semantic-level knowledge inferred by MLLMs and the physics level where robots operate, to ground the object knowledge to physics level and guide object manipulation.

Jianhua Sun*, Yuxuan Li*, Jiude Wei*, Longfei Xu, Nange Wang, Yining Zhang, Cewu Lu§
ICCV 2025
TL;DR
We propose the Articulated Object Procedural Generation (Arti‑PG) toolbox, which synthesizes diverse and unlimited articulated objects with rich annotations through program‑oriented structure manipulation and analytic label alignment, addressing the scarcity of high‑quality articulated object data and annotations.

Discovering Conceptual Knowledge with Analytic Ontology Templates for Articulated Objects
Jianhua Sun*, Yuxuan Li*, Longfei Xu†, Jiude Wei†, Liang Chai, Cewu Lu§
AAAI 2025, Oral
TL;DR
We present AOT and the AOT-driven baseline AOTNet to empower machine intelligence with the kind of human capability to understand and then interact with articulated objects, espeically the novel ones, at the conceptual level for the first time.

ConceptFactory: Facilitate 3D Object Knowledge Annotation with Object Conceptualization
Jianhua Sun*, Yuxuan Li*, Longfei Xu†, Nange Wang†, Jiude Wei†, Yining Zhang, Cewu Lu§
NeurIPS 2024 Datasets and Benchmarks Track
TL;DR
We present ConceptFactory, a novel scope to facilitate more efficient annotation of 3D object knowledge through object conceptualization, containing a unified toolbox for object conceptualization and a large collection of conceptualized objects.
Honors and Awards
- 2021.12: Academic Exellent Scholarship of Shanghai Jiao Tong University
- 2019.12 & 2017.12: First Price, NOIP (National Olympiad in Informatics in Province)
Education
- 2025.09 - Present, M.S., major in Computer Science, SAI, Shanghai Jiao Tong University
- 2021.09 - 2025.06, B.Eng., major in Artificial Intelligence, SEIEE, Shanghai Jiao Tong University